Available for research collaboration

Hrag Djabraian

Mechanical Engineering Researcher/Controls & Robotics/UC San Diego

From airframe fabrication to flight-control integration, building aerial platforms from the hardware up.

0.000
GPA · UC San Diego
0
Languages Spoken
0
Rotors · Research UAV
0
Engineering Teams Led
01
Ethos

About

Rigorous engineering, from first principles to flight test.

B.S. Mechanical Engineering with a Specialization in Controls and Robotics from UC San Diego, conferred September 2026 Magna Cum Laude with a 3.962 GPA and membership in the Tau Beta Pi engineering honor society.

Now reading for a research-based M.S. at UC San Diego in controls and mechatronics, continuing the aerial-robotics research in the same lab.

My background spans aerial vehicle research, embedded electronics, competitive eVTOL development, and hands-on mechanical systems. Research interests center on flight control, estimation, robust control, and robotics for autonomous and dynamic systems.

Focus
Flight control · Estimation · Robust control · Robotics
Education
B.S. MechE · UC San Diego · 3.962 GPA · Magna Cum Laude · Tau Beta PiM.S. Controls & Mechatronics · UC San Diego · 2026–2027
Languages
English · French · Armenian · Arabic · Spanish
Hrag Djabraian
San Diego, CA
02
Featured

Research

Graduate Research

Canted-Rotor Hexacopter Platform

Jan 2026 to Present · Graduate Researcher since Sep 2026

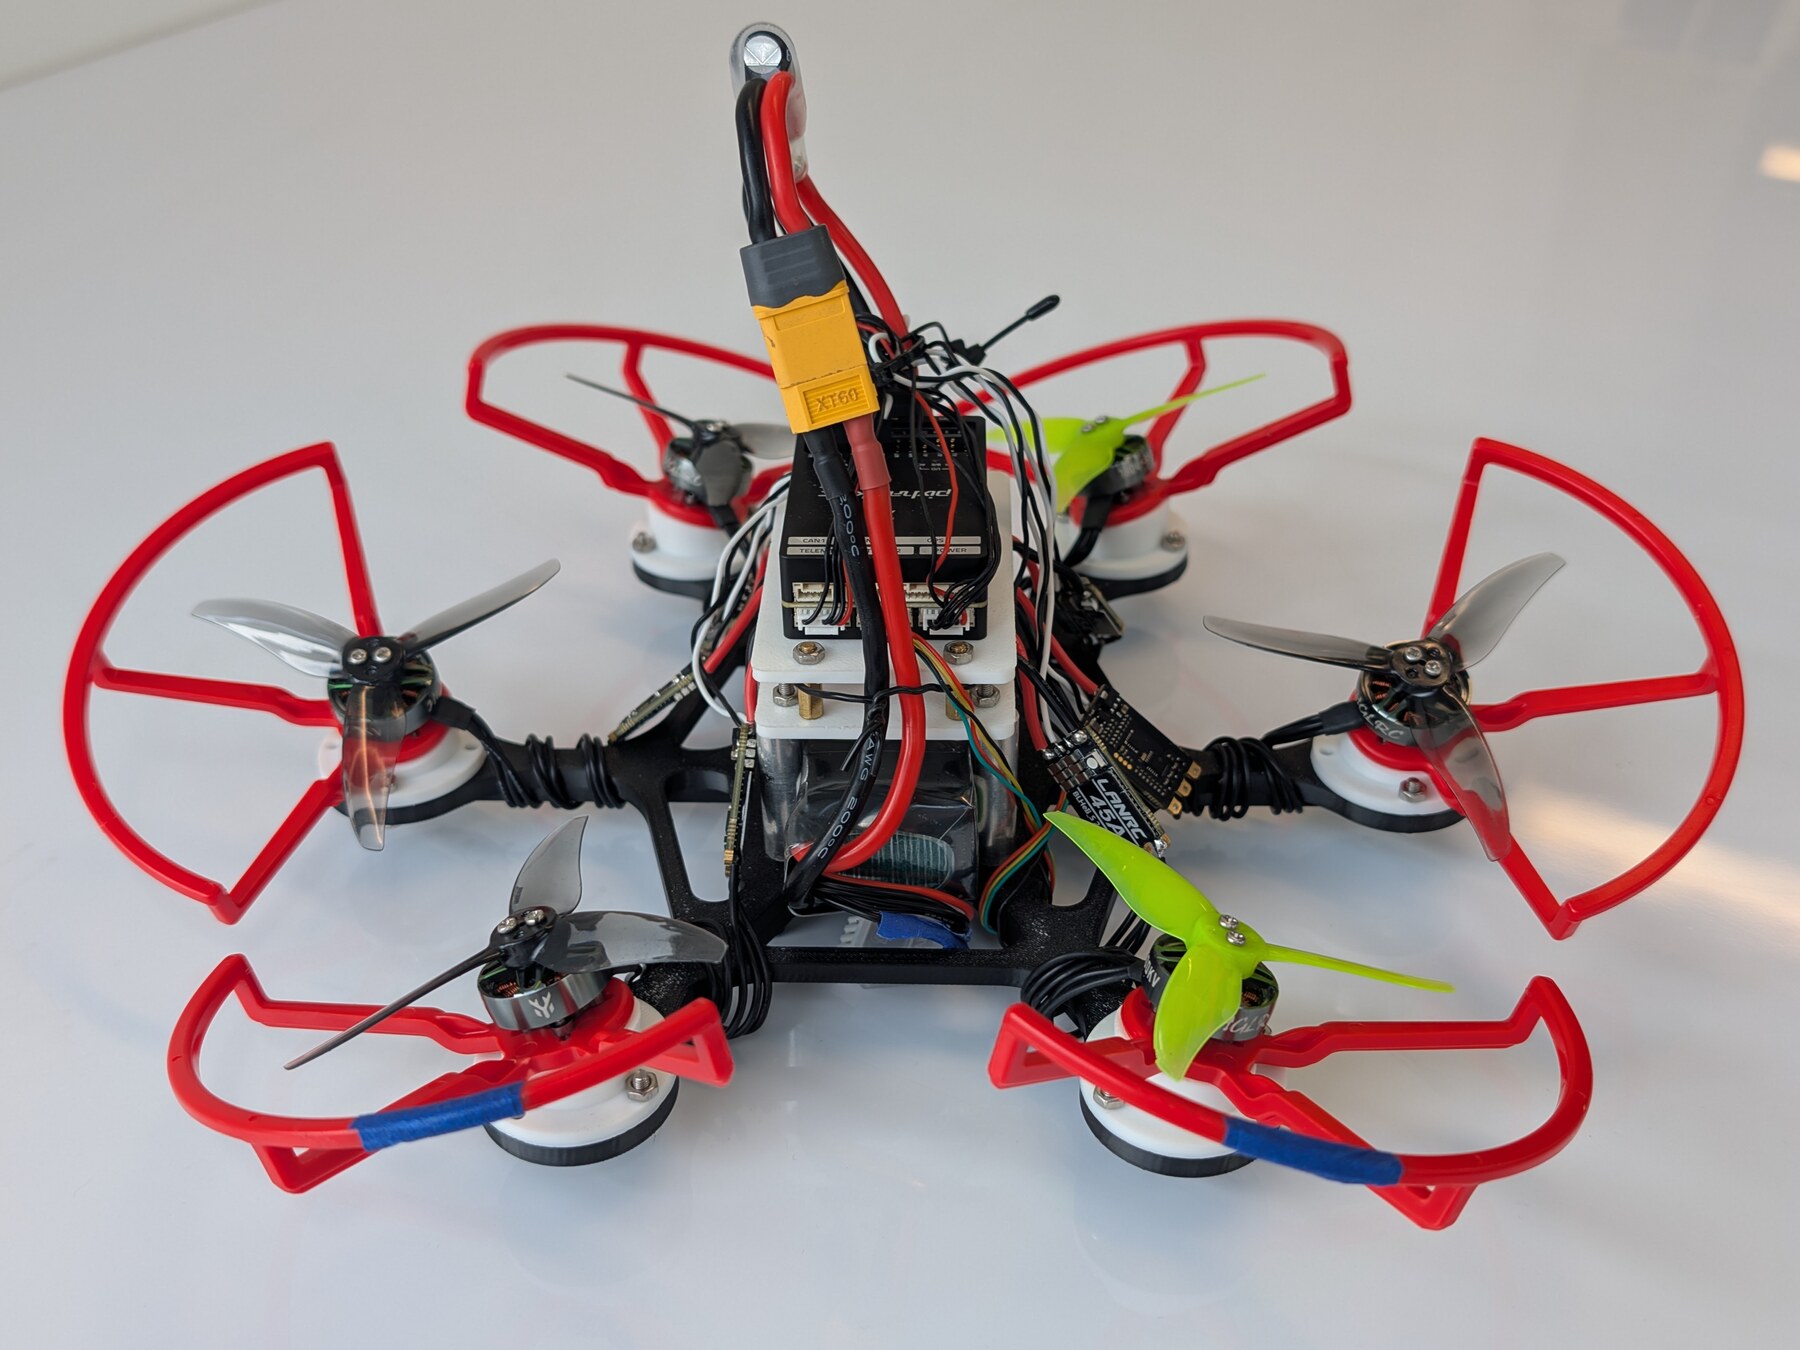
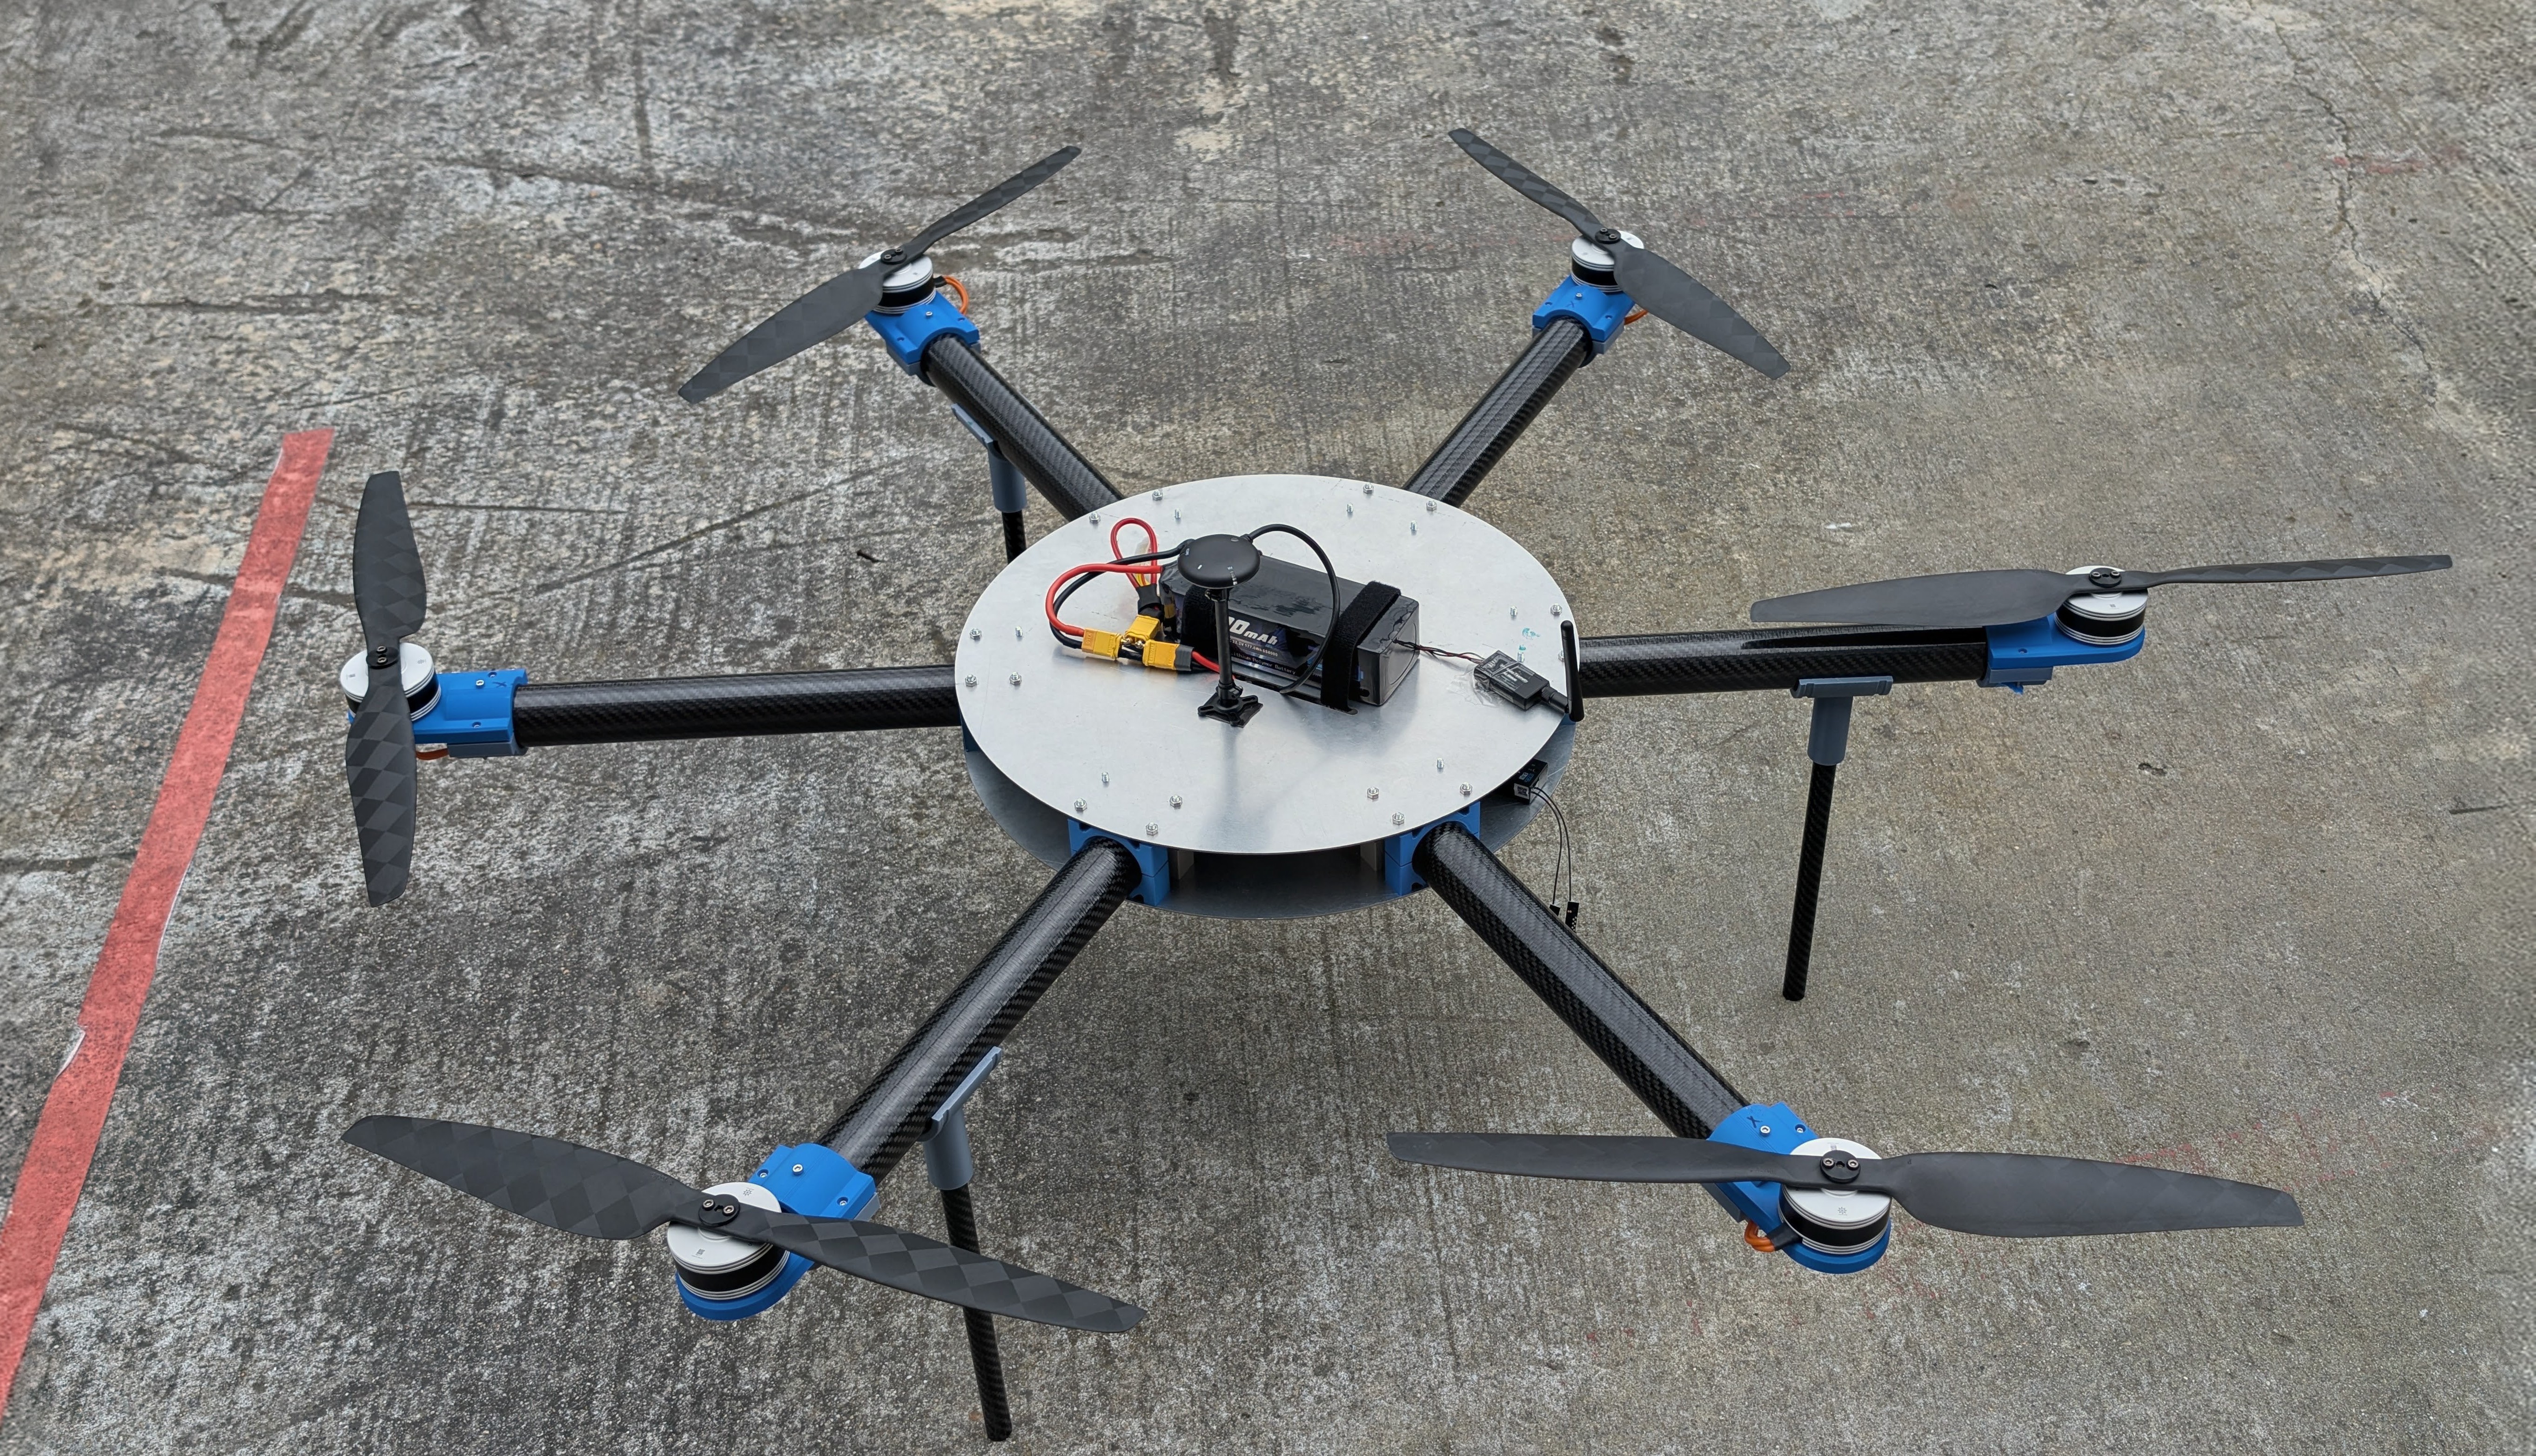
Design, development, and experimental validation of a canted-rotor hexacopter: a six-rotor aircraft that controls all six force and torque components independently, with fixed rotors and no added actuators, so it translates in any direction while holding level. The rotor cant angles come from an integer orthogonal nullspace basis of the conventional mixer, which makes the wrench matrix orthogonal and its inverse closed-form. A custom PX4 flight task bypasses the four-channel mixer and commands the full six-component wrench directly, leaving the estimator, failsafes, and ground-station tooling untouched. Across 8,094 logged samples the aircraft translates at 2.0 to 2.5 m/s² while holding under 3° of tilt, where a coplanar airframe is bound to nearly 13°.

Publications

H. Djabraian, D. Mkrtchian, T. Wan, and T. R. Bewley, “Direct 6-DoF Control of a Canted-Rotor Hexacopter with No Added Actuators,” submitted to the IEEE International Conference on Robotics and Automation (ICRA), Seoul, 2027. Under review.

UAV/Hexacopter/Airframe Design/PX4/Flight Control/Embedded Systems/Fabrication
Canted-rotor hexacopter prototype
Airframe · Front viewFIG. 01
03
Engineering

Experience

Fall 2026San Diego, CA

Teaching Assistant, MAE 144 Embedded Control & Robotics

UCSD Mechanical & Aerospace Engineering

Sole teaching assistant for the department's hands-on embedded controls and robotics course, 61 students, run by the same lab as the hexacopter research above. The course builds real control hardware, so the support load is lab bring-up and debugging rather than problem sets.

Embedded Control/Robotics/Teaching/Lab Instruction
Summer 2026San Diego, CA

Teaching Assistant, MAE 143B Linear Control

UCSD Mechanical & Aerospace Engineering

Wrote the grading rubrics and graded homework sets and a midterm for a 55-student classical control course.

Linear Control/Teaching/Assessment
Sep 2025 – Sep 2026San Diego, CA

Project Manager & Controls/Electronics Lead

UCSD DBVF Team

Led coordination across four engineering teams (Airframe, Embedded Controls, Software/Automation, and Proposal) developing a wildfire-response eVTOL for the 2025–2026 Vertical Flight Society Design Competition. Directed the Embedded Controls team in design and analysis of the aircraft's power and control systems (batteries, PDB, ESCs, flight controller, sensors). Owned technical documentation including the Safety and Risk Plan, Wiring Plan, and Final Technical Report.

eVTOL/Flight Controller/Power Systems/Team Leadership/Technical Documentation
UCSD DBVF eVTOL
Oct 2021 – Jan 2024Los Angeles, CA

Apprentice Mechanic

A Certified Autowork Inc.

Diagnosed and repaired mechanical systems across a wide range of vehicles, from carbureted engines to modern computer-controlled drivetrains. Serviced and overhauled powertrain, suspension, and braking systems on high-performance vehicles to strict engineering tolerances. Introduced data-driven diagnostics using OBD-II and digital repair repositories. Prepared technical reports and warranty claims, securing over $11,000 in reimbursements.

Mechanical Systems/Diagnostics/Technical Reporting
A Certified Autowork
04
Selected Work

Projects

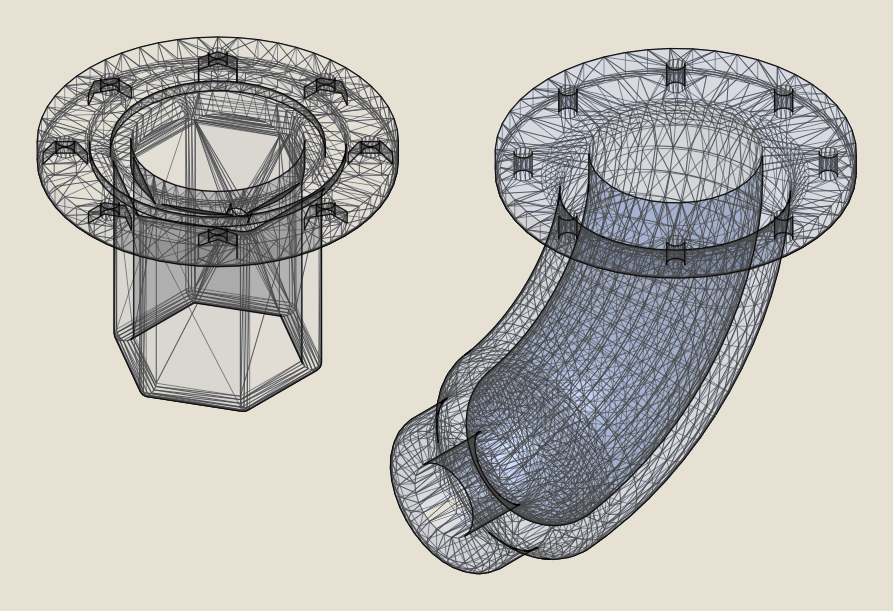
Wireframe mesh render of fluid overflow chute and tubing assembly
P-01Jul 2024

Fluid Overflow Management Component

Independent Project

Designed and fabricated a 3D-printed chute-and-tubing system to capture and redirect overflow fluid from a pressurized jet apparatus used in fluid flow and heat transfer research. Iterated CAD models to optimize fit, flow routing, and durability. Final design successfully contained excess fluid, enabled recovery for reuse, and prevented equipment damage. Designed to be adaptable for closed-loop fluid reservoir integration.

CAD/Additive Manufacturing/Fluid Systems/Prototyping
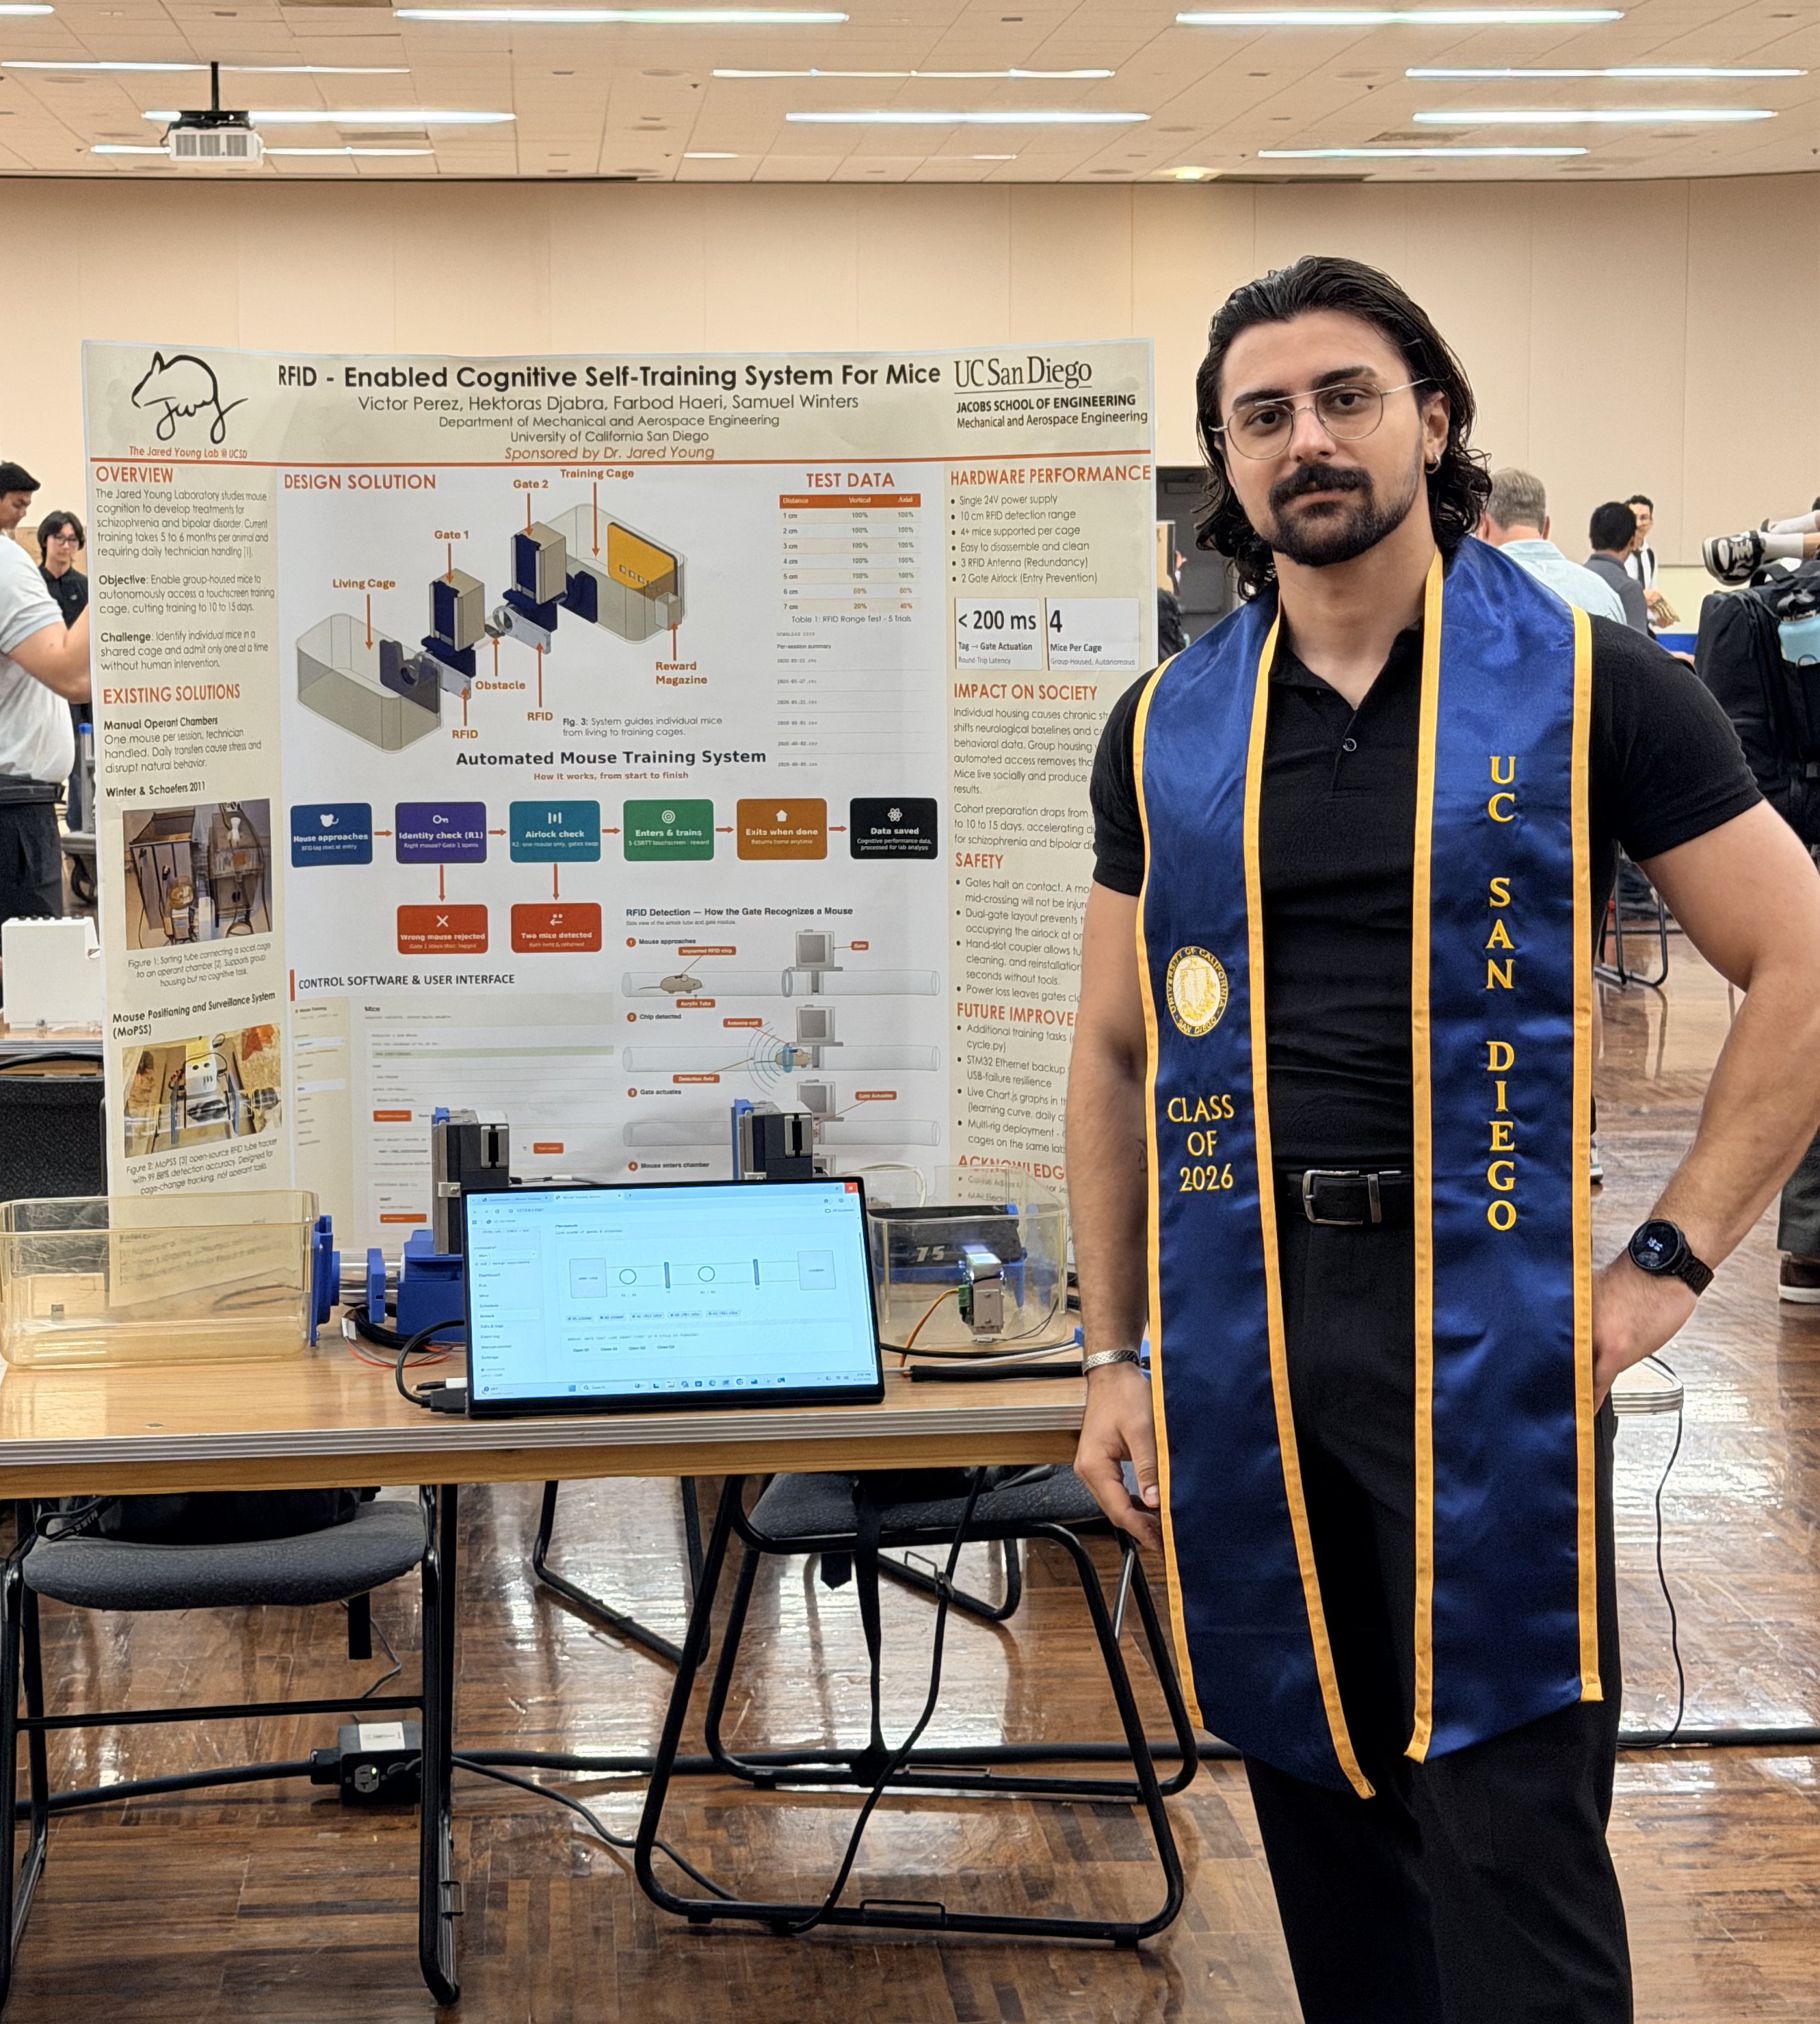
Senior design expo with prototype
P-02Spring 2026

RFID-Enabled Cognitive Self-Training System for Mice

MAE 156B Senior Design Capstone, UC San Diego
Sponsor: Dr. Jared Young, UCSD Health
Team: Victor Perez, Farbod Haeri, Samuel Winters, Hrag Djabraian

Designed and built an RFID-controlled dual-guillotine gate airlock system connecting a group-housing cage to an existing touchscreen training chamber. Passive RFID transponders implanted in each mouse allow the system to identify individual animals and enforce single-occupancy access automatically, eliminating manual handling and individual housing. Reduced cohort training time from 5 to 6 months down to 10 to 15 days. Measured ~430 ms from tag detection to gate fully open against a 500 ms requirement, and supports 4 or more mice per cage simultaneously. Delivered to the lab for use.

RFID/Embedded Systems/CAD/Additive Manufacturing/Control Software/Biomedical
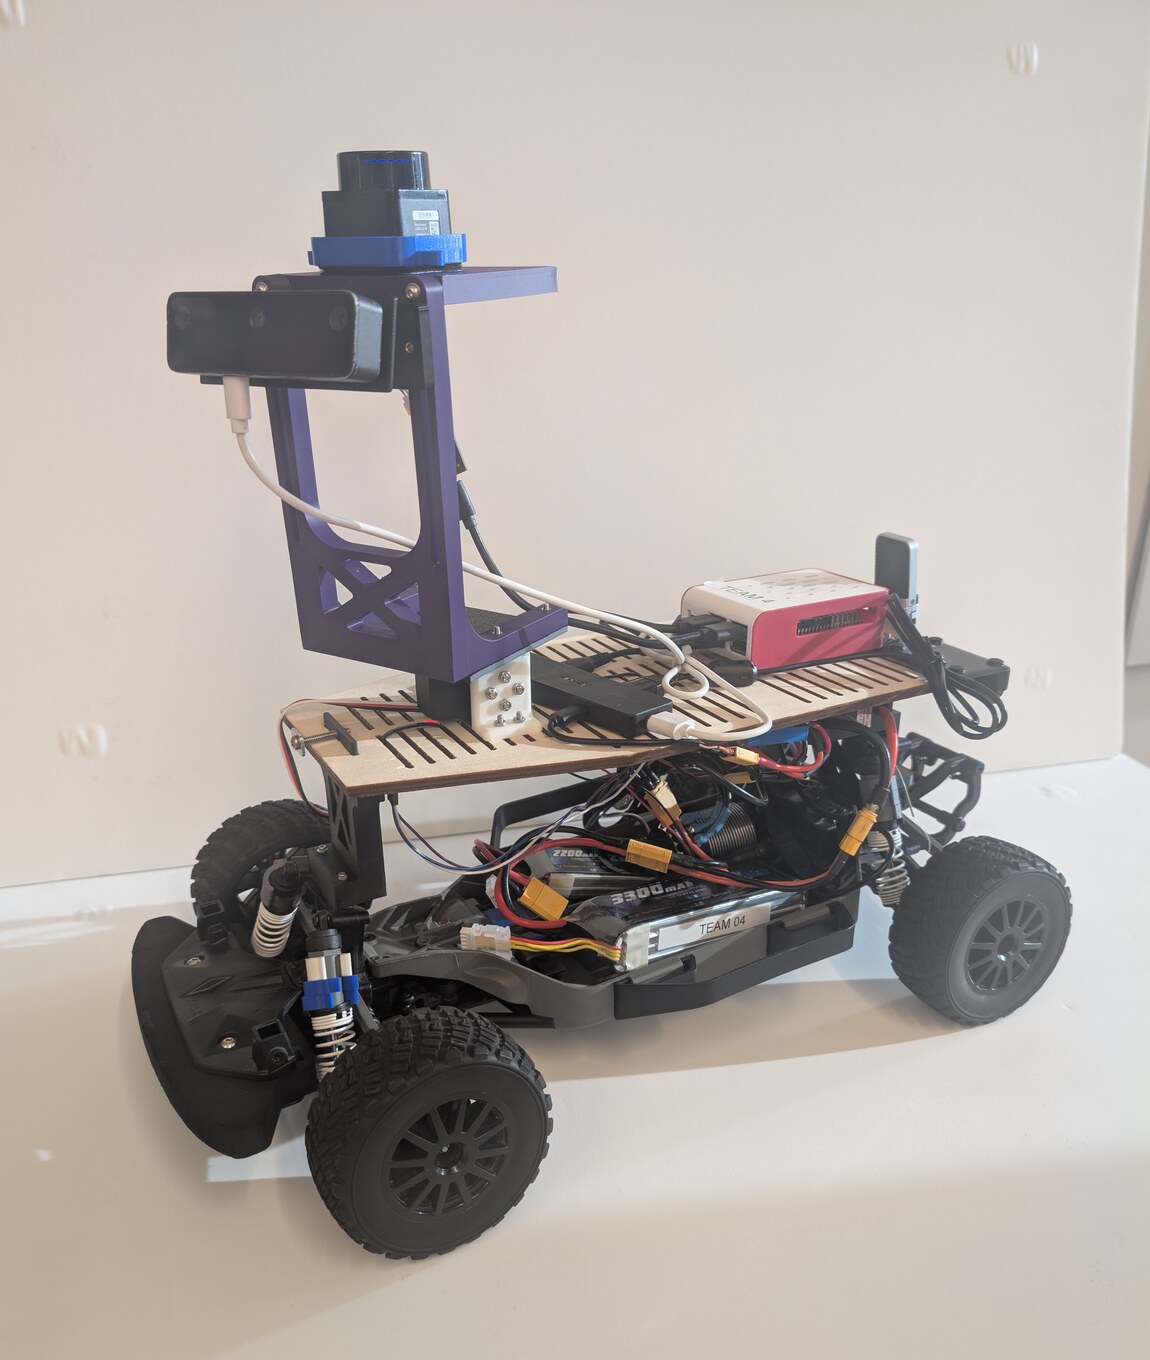
Doggobot autonomous robocar with OAK-D depth camera and onboard compute
P-03Jun – Sep 2026

Autonomous Voice-Commanded Robocar

MAE/ECE 148 · UC San Diego
Team 4 · Final grade A+

A 1/10-scale autonomous vehicle that takes spoken commands, follows a person using stereo depth, and brings its own autonomy stack up at power-on. Compute is split off the vehicle across three machines: speech recognition in a phone web app, language parsing on a remote GPU across a private mesh network at a measured 35 ms round trip, and object detection on the camera's own vision processor. The person detector was trained without hand-labelled data, using an open-vocabulary teacher to auto-label 5,000 images and distilling into a YOLO11n student at mAP50 0.816, deployed to a Myriad X VPU at 25.6 fps. The ROS 2 stack is arranged so exactly one node publishes to /cmd_vel, arbitrating voice, autonomy, and safety by priority behind a killswitch that bypasses speech recognition entirely.

ROS 2/Computer Vision/Edge AI/Stereo Depth/RTK-GNSS/Embedded Linux
05
In Service

AI Tracking Turret

v2 · In daily useDeployed as a multi-camera security system

A real-time visual servoing platform: a two-axis pan-tilt turret that detects, estimates, and follows moving targets using computer vision and closed-loop control. The camera sits on the moving axes, so the sensor and the plant are coupled and the loop has to lead the target rather than chase it. Built end to end: mechanism, firmware, vision pipeline, state estimation, control law, and a browser control surface. The plant was identified by step-response sweep and LQR and LQG designed against it, running alongside PID on the hardware.

SENSORGlobal-shutter camera, mounted on the moving axes
VISIONGPU detection at ~40 fps; loop runs at 120 fps camera rate
ESTIMATIONPer-axis Kalman filter on target position and velocity
FEEDFORWARDProximity-gated lead, scaled by lock state
CONTROLPID, LQR and LQG from step-response system identification
ACTUATIONSerial-bus servos with absolute encoders · Teensy 4.0
ACCESSIdentity-gated web HUD · no port exposed
MODESTrack · Pointer · Joystick · Sentry sweep

Next objective: autonomous lock-on and tracking of the canted-rotor hexacopter in flight, closing the loop between both research platforms.

Target acquisition
06
Praxis

Skills

Controls & Autonomy

I
  • PID Control Design & Tuning
  • State Estimation (Kalman Filtering)
  • Flight Control (PX4)
  • Visual Servoing
  • Dynamic System Modeling
  • Real-Time Control Implementation

Software

II
  • MATLAB
  • Python
  • C++
  • Linux · Git
  • Computer Vision (MediaPipe, YOLO)
  • Web Development (React, HTML/CSS)

Design & Manufacturing

III
  • CAD (SolidWorks, Inventor)
  • CAM & CNC Machining
  • Manual Mill & Lathe
  • Additive Manufacturing
  • FEA · CFD
  • Design for Manufacturability

Embedded & Electrical

IV
  • Microcontrollers (Teensy, Arduino)
  • Sensor Integration & Serial Comms
  • Wiring & Soldering
  • Power Systems & Distribution
  • Flight-Controller Integration (Pixhawk)
  • Data-Driven Diagnostics (OBD-II)

Leadership & Practice

V
  • Project Management
  • Cross-Functional Team Leadership
  • Technical Reporting
  • Safety & Risk Planning
  • Stakeholder & Sponsor Communication
  • LaTeX · Excel · Notion

Languages

VI
  • English
  • French
  • Armenian
  • Arabic
  • Spanish
«Ἦθος ἀνθρώπῳ δαίμων»

"Character is destiny."

Heraclitus

07

CV & Contact

Let's build something rigorous.

Open to research collaborations, graduate opportunities, and engineering conversations. Reach out directly or grab the latest CV.

Download CV (PDF)